Atharva Joshi

Research Interests
I am interested in the design and development of robotic and mechatronic systems that improve efficiency, safety, and quality of life. I enjoy exploring applications that integrate automation, sensors, and human-machine interaction, particularly in settings where autonomous systems can enhance safety or support learning. My goal is to contribute to projects that combine mechanical design with robotics and Industry 4.0 technologies.
Education
B.S. Mechanical Engineering, Minor: Mechatronics
The Pennsylvania State University
Graduation: December 2026
Human-Centered Robotics Lab Project
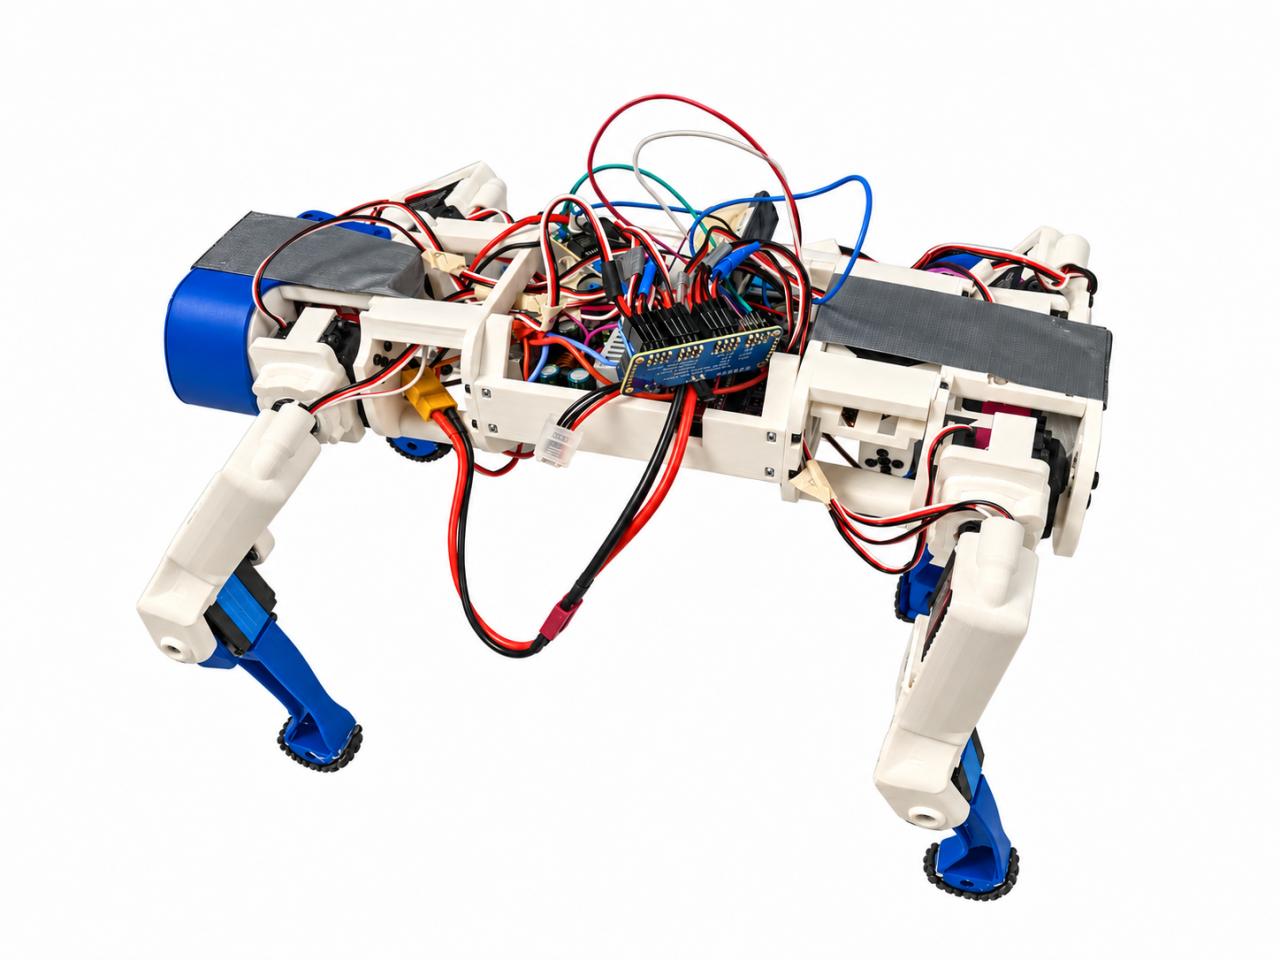
Spot Micro Quadruped Robot Dog
This project is essentially about bringing a Spot Micro Quadruped to life. It’s a 12-servo robot dog inspired by the famous Boston Dynamics designs, built to mimic the way a real animal moves.
The basic architecture revolves around two microcontrollers- Teensy 4.0, and Arduino Nano, and an IMU- MPU6050. So far, I've successfully demonstrated the robot's multi-directional pitch and roll auto-levelling capabilities .
A brief summary of the control algorithm used is as follows:
A 50 Hz closed-loop PD controller fuses MPU6050 gyro and accelerometer data via an adaptive, vibration-rejecting complementary filter to dynamically level the body by differentially compressing and extending all four legs with slew-rate-limited servo corrections.
Professional Experience
Undergraduate Research Assistant
Human-Centered Robotics Lab, Penn State
University Park, PA
Mechanical Engineering Intern
TE Connectivity
Middletown, PA
Mechanical Integrity Engineering Intern
Amphenol Communication Solutions
Etters, PA
Undergraduate Research Assistant
S.H.A.P.E. Lab, Penn State
State College, PA
Lab Technician
OriginLabs Penn State
State College, PA